System overview
Elena is organized around three named computing roles.
Mother
Mother is the Windows PC application. It accepts live TCP telemetry and commands, records Elena's activity, sends messages to the connected client, and provides access to Ollama.
Nolena
Nolena is a Raspberry Pi Pico 2 W. It controls the four motors through the Yahboom controller, reads Qwiic/I²C and infrared sensors, connects to Mother over Wi-Fi, and exchanges display commands with Melissa.
Melissa
Melissa is a Waveshare RP2040-Plus with 16 MB of flash. It communicates with Nolena through UART and manages Elena's E-Ink display.
Communications
| Connection | Transport | Purpose |
|---|---|---|
| Mother ↔ Nolena | Wi-Fi/TCP, port 9090 | Telemetry and commands |
| Nolena ↔ Melissa | UART, 3.3 V logic | Display commands and status |
| Nolena ↔ Yahboom | I²C, 3.3 V logic | Motor control and feedback |
| Nolena ↔ sensors | Qwiic/I²C | Environmental and navigation data |
Power architecture
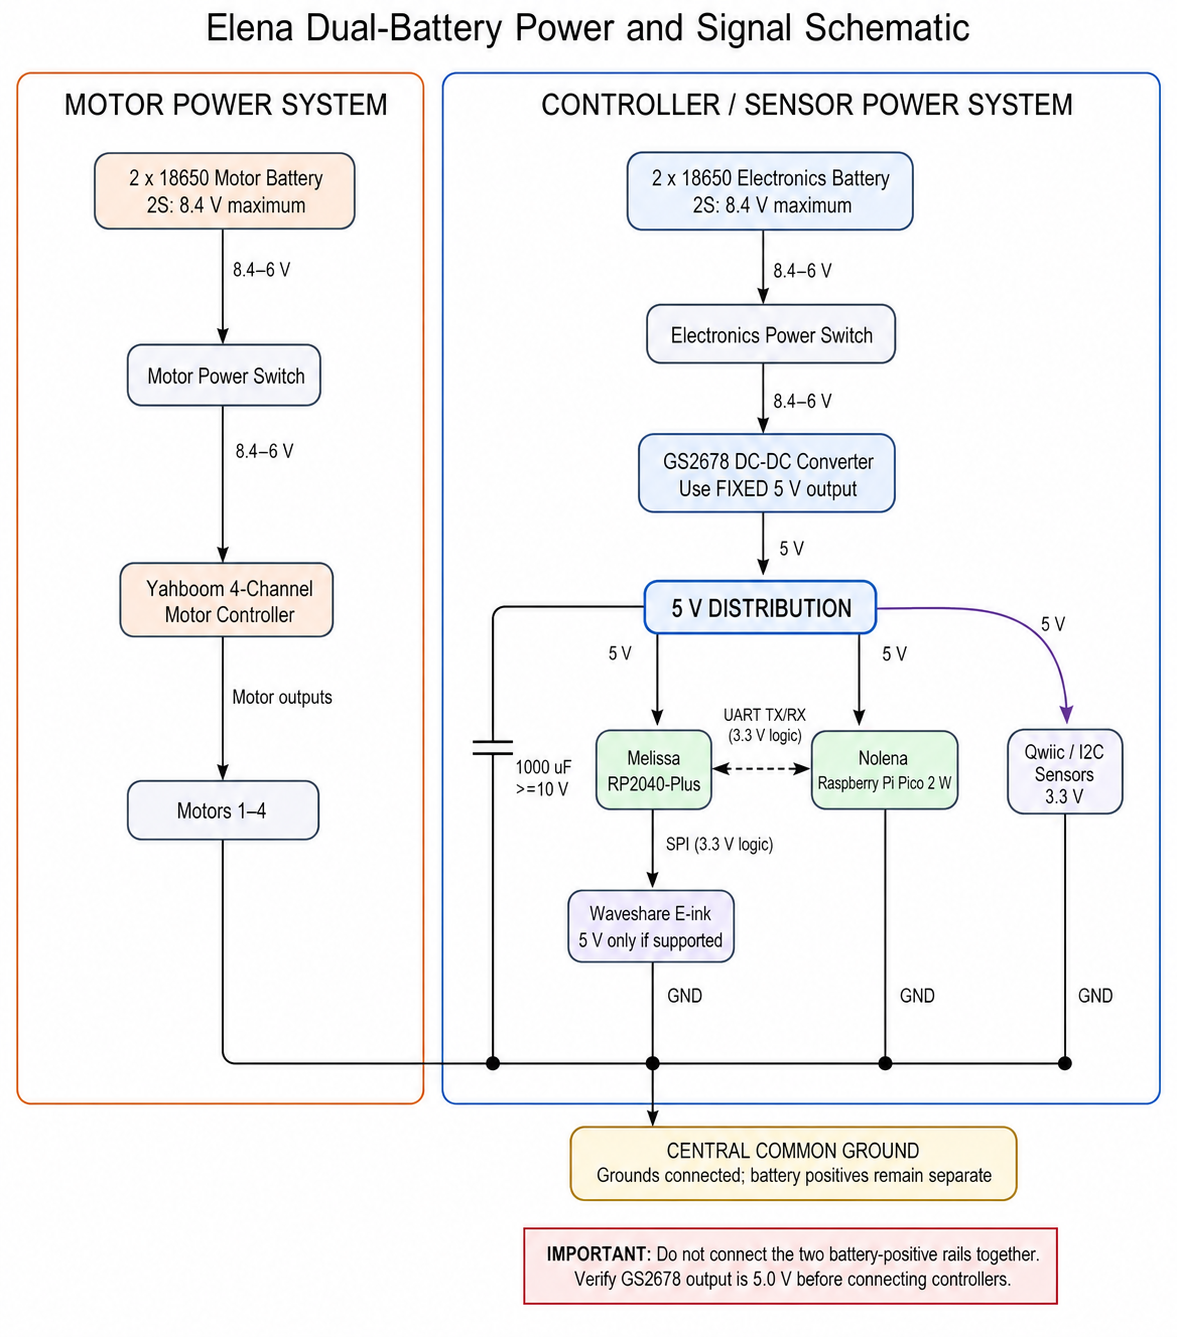
Elena uses separate 2S battery packs for motor power and controller power. The GS2678 converts the electronics battery voltage to a regulated 5 V rail that powers both Nolena and Melissa. The grounds are joined for signal reference, but the positive battery rails are not connected together.
The present build does not include separate 2S BMS/charging modules or inline fuses. Each battery feeds its load through its power switch.